ROS package for track and follow of a moving person
The Idea
Helping a robot understand where to go next.
This project explored how a mobile robot can recognize a moving person, keep track of them and follow them through a real environment. First, the robot learned to detect a person and rotate towards them. Then, it combined rotation and translation to follow them while keeping a safe distance.
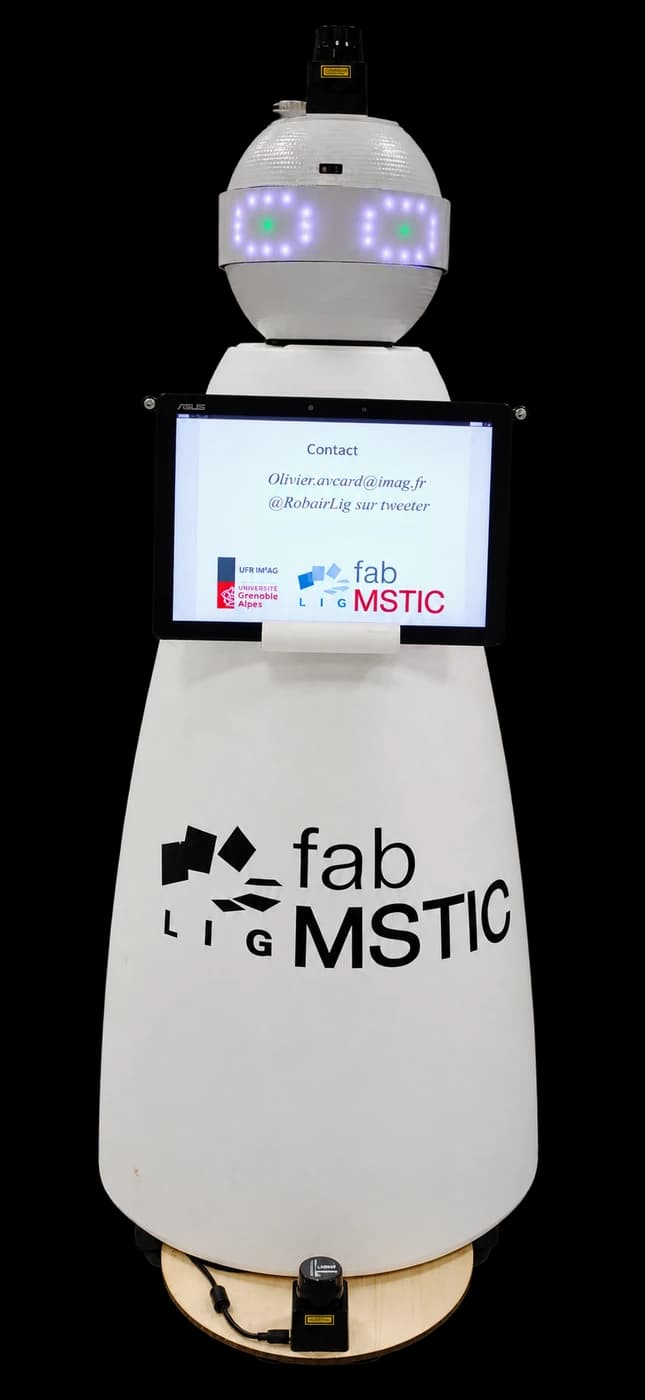
Detect
The robot identifies a moving person in its surroundings.
Track and follow
It combines turning and forward movement to follow smoothly.
Stay oriented
It compares its sensor readings with a map to correct position drift.
What I worked on
Building robust perception and control for mobile robots.
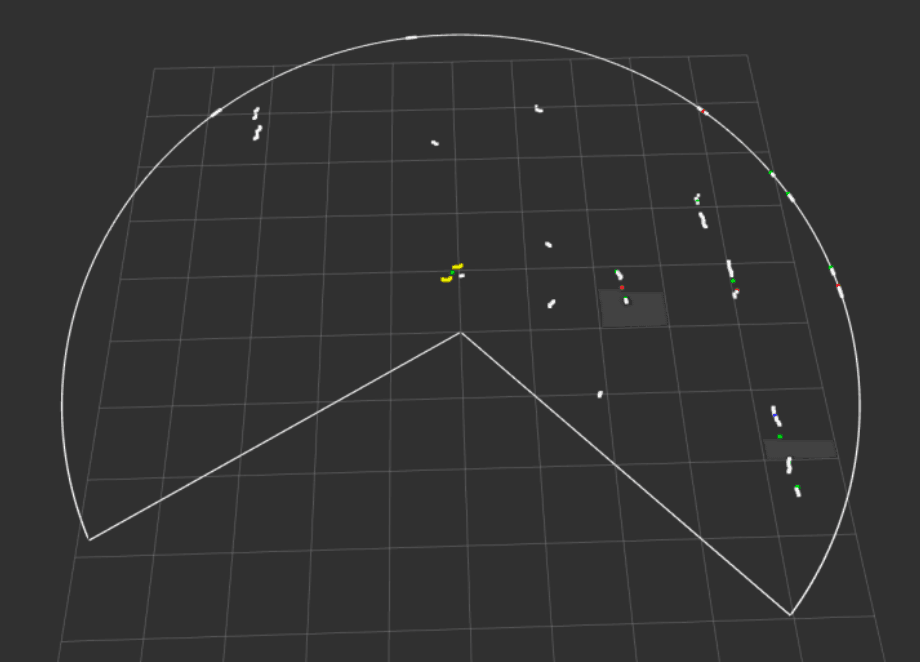
I worked on the complete loop from laser data to robot motion: detecting a moving person, maintaining a reliable track and translating that estimate into smooth, safe behaviour.
This project strengthened my ability to work with ROS, LiDAR sensing, RViz visualisation and real-time control, while tuning a system to remain responsive in changing environments.
Navigation and localisation
Connecting perception to the robot's position.
I also worked with scan matching: comparing successive laser scans with the surrounding map to estimate movement and reduce drift in the robot’s position and direction.
Stack I am comfortable working with